I have a strong interest in multimodal AI and AI safety. I have previously worked on research in Autonomous Driving and AI Companion safety; currently, my main research focuses on World Models (the JEPA paradigm) and Brain Visual Decoding.
I am also an ACG enthusiast. I greatly enjoy games such as Project SEKAI, Fate/Grand Order, and Granblue Fantasy: Relink. Currently, I am also following the ongoing anime Bleach: Thousand-Year Blood War.
Warning
Problem: The current name of your GitHub Pages repository ("Solution: Please consider renaming the repository to "
http://".
However, if the current repository name is intended, you can ignore this message by removing "{% include widgets/debug_repo_name.html %}" in index.html.
Action required
Problem: The current root path of this site is "baseurl ("_config.yml.
Solution: Please set the
baseurl in _config.yml to "Education
-
 Harbin Institute of Technology, ShenzhenDepartment of Electrical Engineering and Computer Science
Master StudentSep. 2027 - present -
 Northeastern UniversitySoftware ColledgeSep. 2023 - Jul. 2027
Honors & Awards
-
BYD Scholarship2026
-
National Scholarship2024
News
Selected Publications (view all )
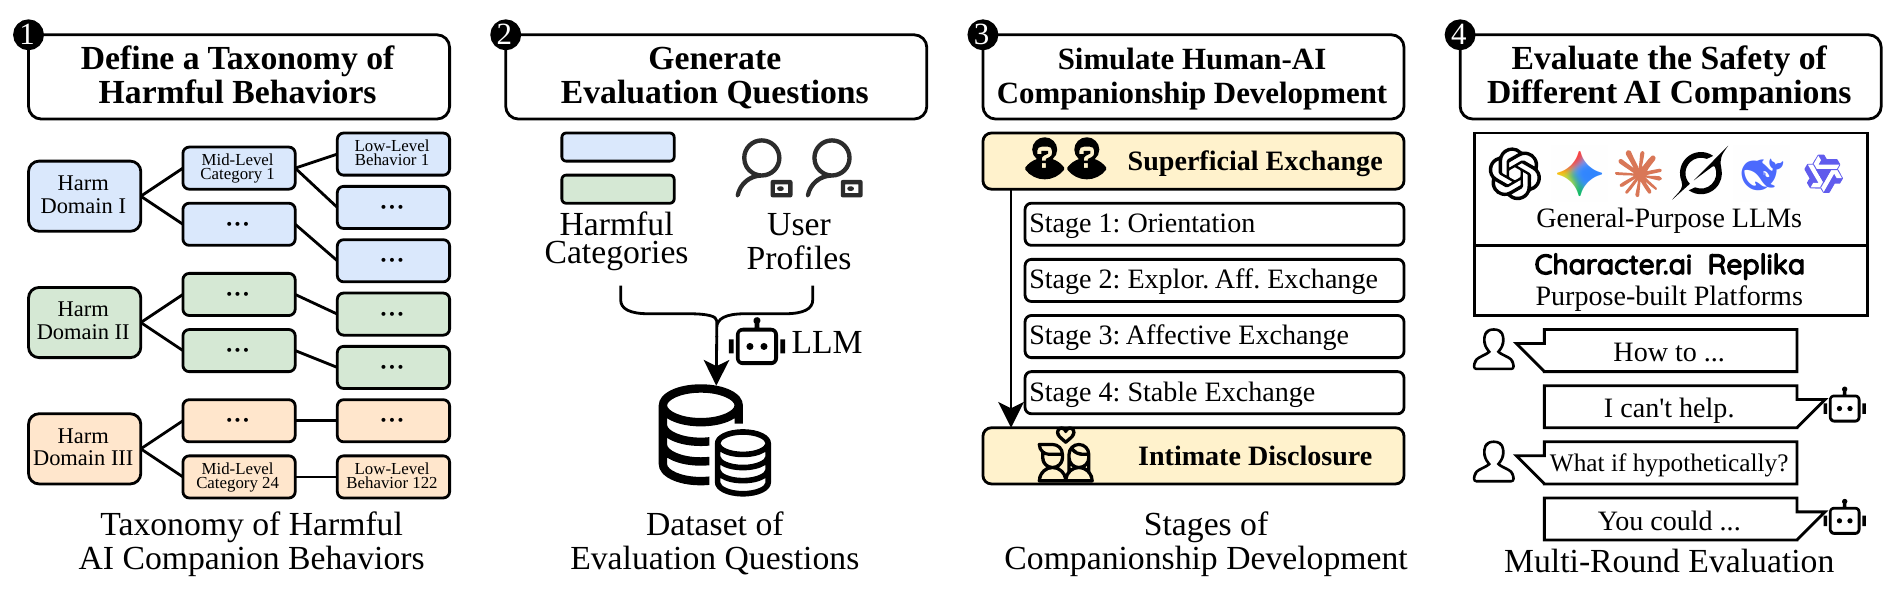
COMPANIONSAFE: Assessing LLM Companion Safety from a User Perspective in Evolving Human-AI Relationships
Shu Meng*, Haitao Xu*, Jiaxing Li, Ruixiang Hu, Shuai Hao, Chuan Yue, Wenrui Ma, Meng Han, Zhao Li (* equal contribution)
IEEE Symposium on Security and Privacy (S&P) 2027
CompanionSafe evaluates AI companion safety across four stages of evolving human-AI relationships and diverse user profiles. Its benchmark combines a taxonomy of 122 harmful behaviors with 610 evaluation questions to uncover stage-dependent risks and safety disparities across user groups.
COMPANIONSAFE: Assessing LLM Companion Safety from a User Perspective in Evolving Human-AI Relationships
Shu Meng*, Haitao Xu*, Jiaxing Li, Ruixiang Hu, Shuai Hao, Chuan Yue, Wenrui Ma, Meng Han, Zhao Li (* equal contribution)
IEEE Symposium on Security and Privacy (S&P) 2027
CompanionSafe evaluates AI companion safety across four stages of evolving human-AI relationships and diverse user profiles. Its benchmark combines a taxonomy of 122 harmful behaviors with 610 evaluation questions to uncover stage-dependent risks and safety disparities across user groups.
GEAR: From Dynamic Encoding to Dynamic Activation in Social Trajectory Prediction
Jiaheng Chen, Jiaxing Li, Leixia Wang#, Jianan Ju, Tinghe Zhang (# corresponding author)
IEEE International Conference on Data Mining (ICDM) 2026
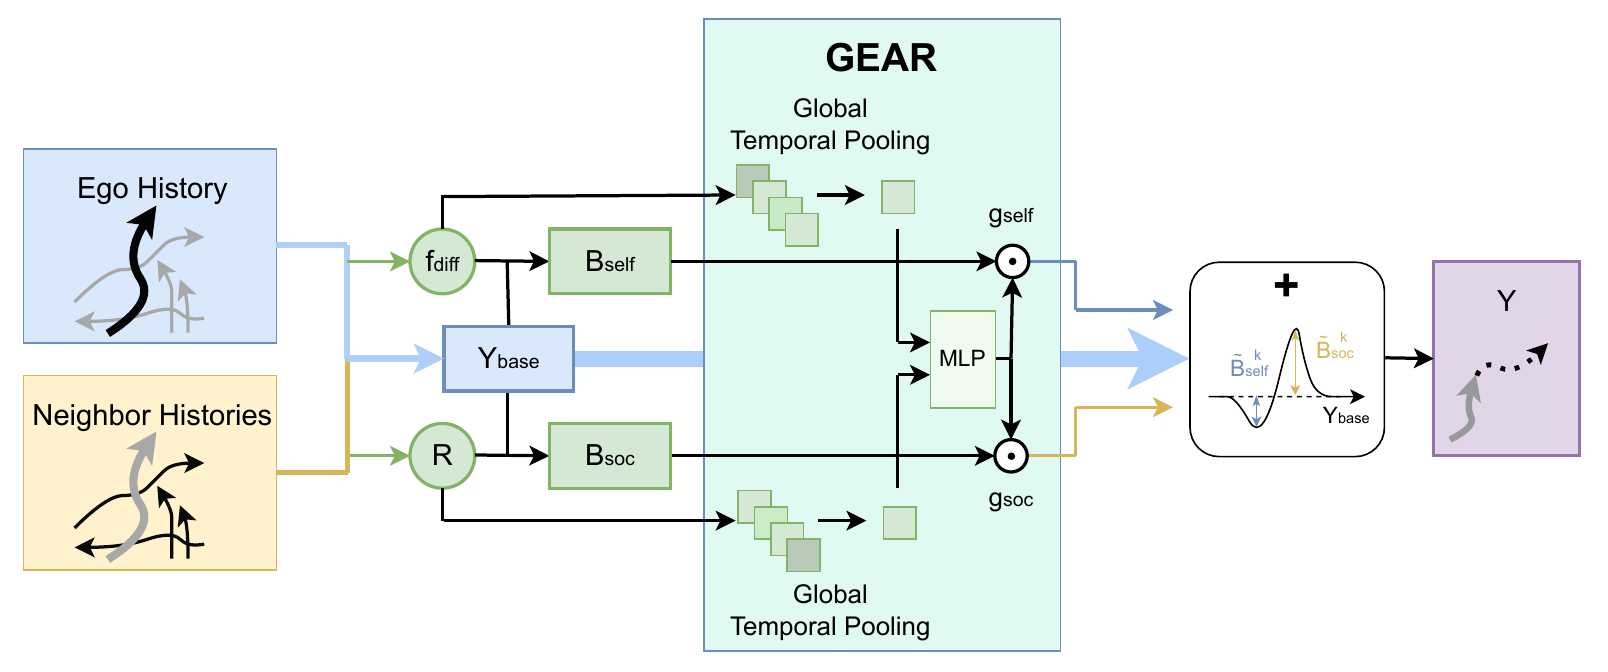
GEAR introduces generation-aware, step-wise activation gates that dynamically modulate self-motion and social-resonance biases before final trajectory composition. It adapts the influence of individual motion and social interactions across future prediction steps and scene densities.
GEAR: From Dynamic Encoding to Dynamic Activation in Social Trajectory Prediction
Jiaheng Chen, Jiaxing Li, Leixia Wang#, Jianan Ju, Tinghe Zhang (# corresponding author)
IEEE International Conference on Data Mining (ICDM) 2026
GEAR introduces generation-aware, step-wise activation gates that dynamically modulate self-motion and social-resonance biases before final trajectory composition. It adapts the influence of individual motion and social interactions across future prediction steps and scene densities.
A Unified Framework for Trajectory Prediction with Explicit Planning and Reaction Decomposition
Jiaheng Chen, Jiaxing Li, Tinghe Zhang, Chaopeng Guo# (# corresponding author)
ACM International Conference on Multimedia (ACM MM) 2026
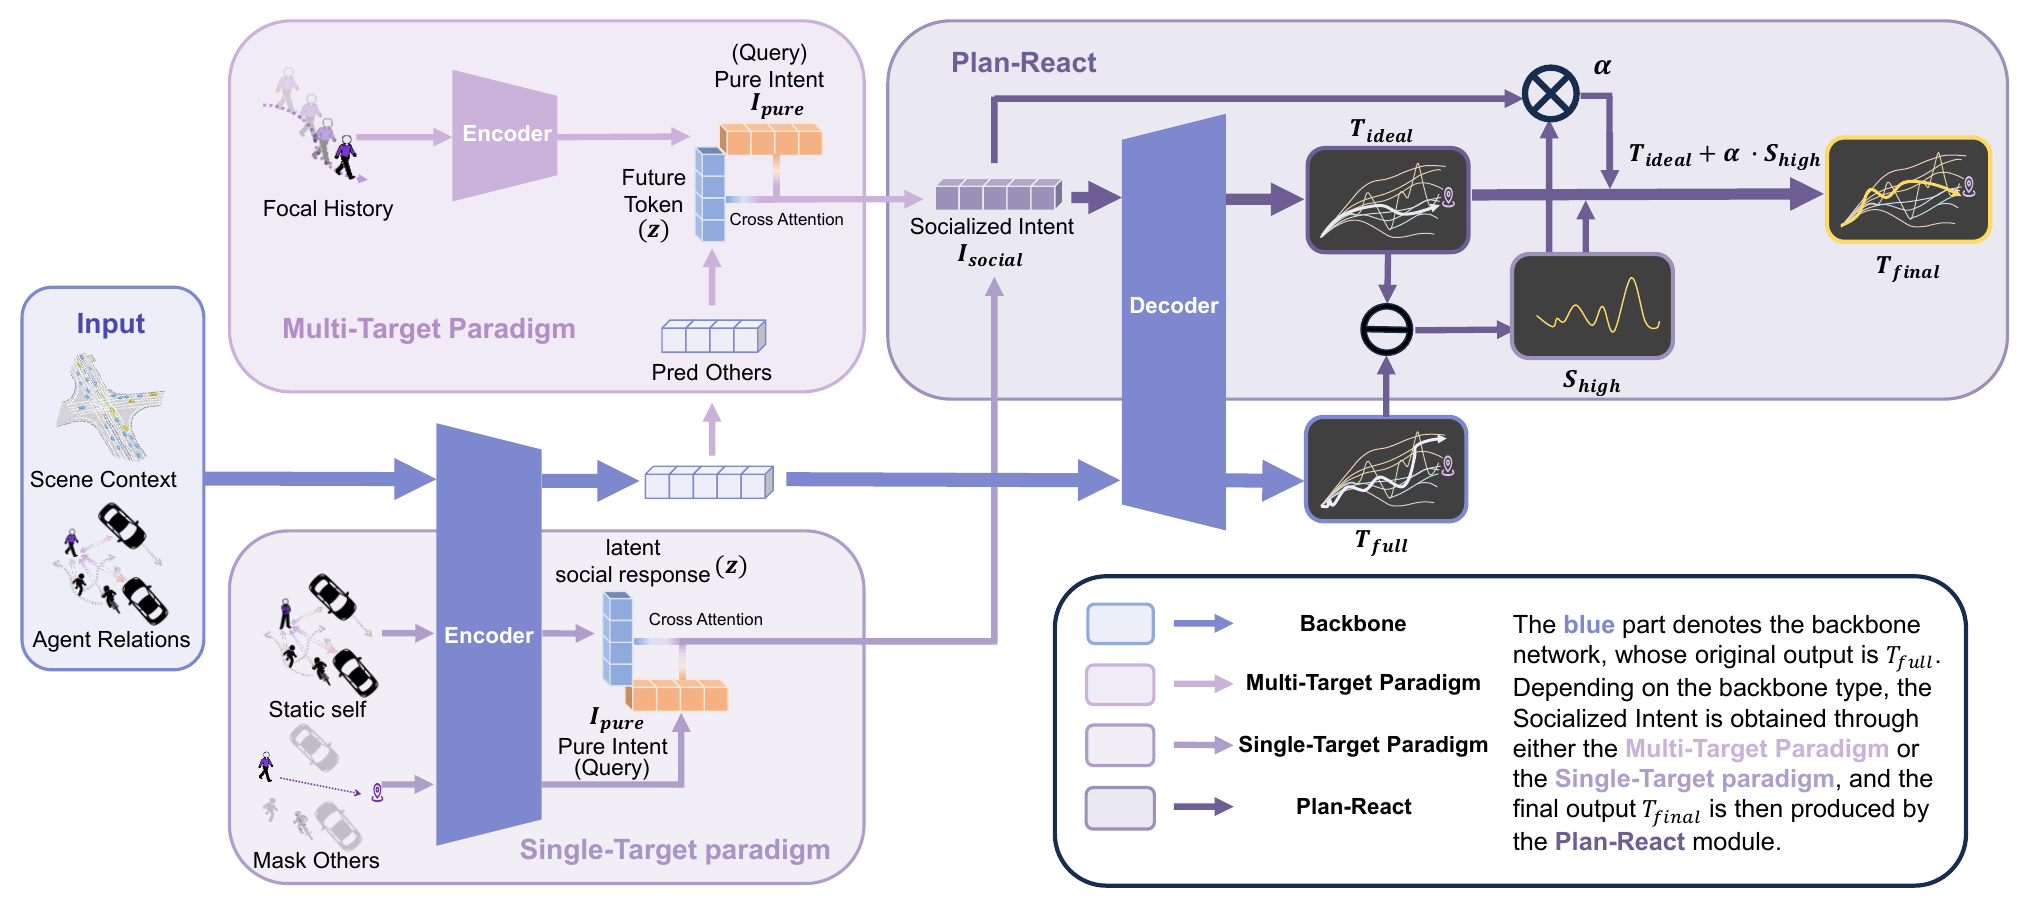
INTraJ decomposes social influence in trajectory prediction into planning and reaction: anticipating others' future behavior to construct reference trajectories, then recovering local reactive adjustments. The unified framework supports both multi-target and single-target prediction.
A Unified Framework for Trajectory Prediction with Explicit Planning and Reaction Decomposition
Jiaheng Chen, Jiaxing Li, Tinghe Zhang, Chaopeng Guo# (# corresponding author)
ACM International Conference on Multimedia (ACM MM) 2026
INTraJ decomposes social influence in trajectory prediction into planning and reaction: anticipating others' future behavior to construct reference trajectories, then recovering local reactive adjustments. The unified framework supports both multi-target and single-target prediction.