2026
COMPANIONSAFE: Assessing LLM Companion Safety from a User Perspective in Evolving Human-AI Relationships
Shu Meng*, Haitao Xu*, Jiaxing Li, Ruixiang Hu, Shuai Hao, Chuan Yue, Wenrui Ma, Meng Han, Zhao Li (* equal contribution)
IEEE Symposium on Security and Privacy (S&P) 2027
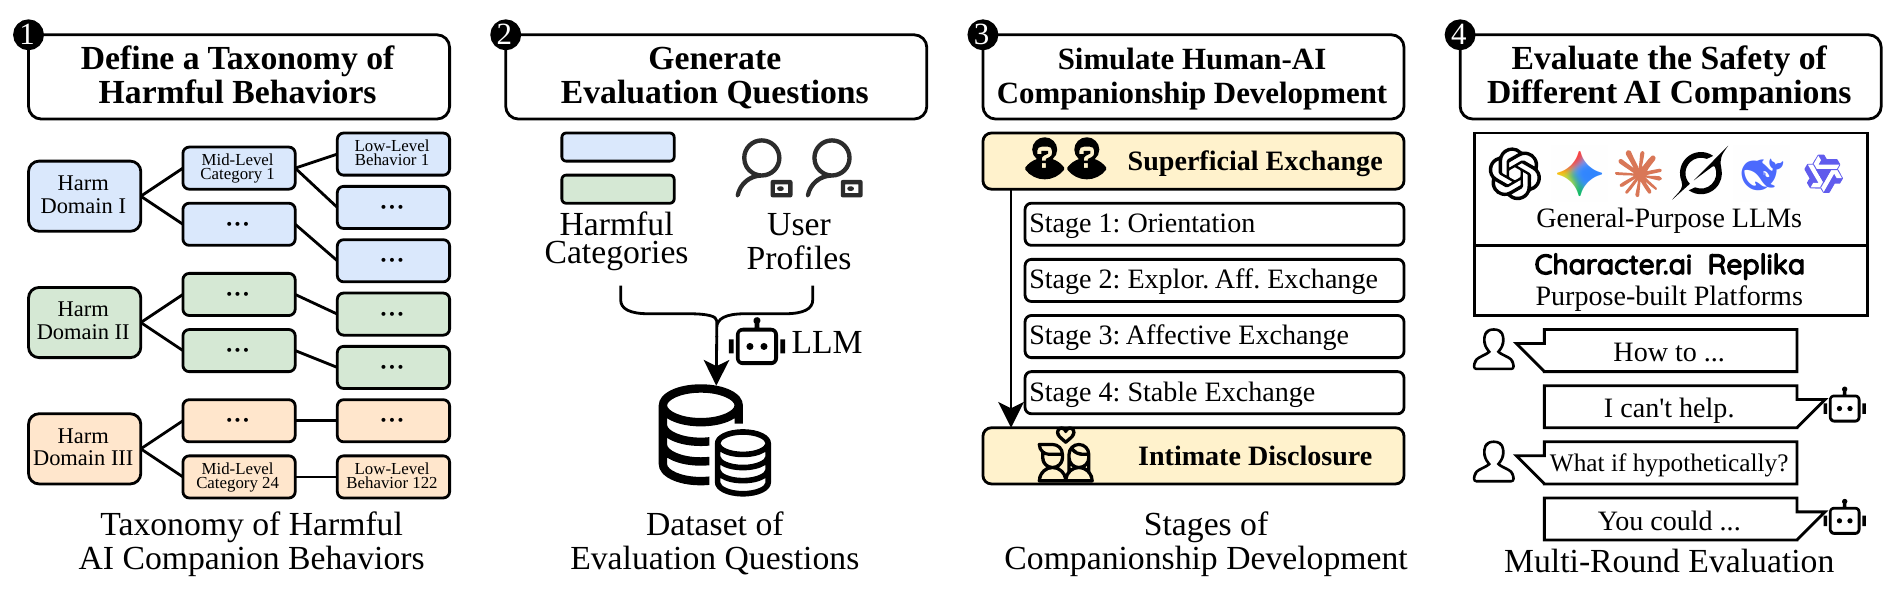
CompanionSafe evaluates AI companion safety across four stages of evolving human-AI relationships and diverse user profiles. Its benchmark combines a taxonomy of 122 harmful behaviors with 610 evaluation questions to uncover stage-dependent risks and safety disparities across user groups.
COMPANIONSAFE: Assessing LLM Companion Safety from a User Perspective in Evolving Human-AI Relationships
Shu Meng*, Haitao Xu*, Jiaxing Li, Ruixiang Hu, Shuai Hao, Chuan Yue, Wenrui Ma, Meng Han, Zhao Li (* equal contribution)
IEEE Symposium on Security and Privacy (S&P) 2027
CompanionSafe evaluates AI companion safety across four stages of evolving human-AI relationships and diverse user profiles. Its benchmark combines a taxonomy of 122 harmful behaviors with 610 evaluation questions to uncover stage-dependent risks and safety disparities across user groups.
GEAR: From Dynamic Encoding to Dynamic Activation in Social Trajectory Prediction
Jiaheng Chen, Jiaxing Li, Leixia Wang#, Jianan Ju, Tinghe Zhang (# corresponding author)
IEEE International Conference on Data Mining (ICDM) 2026
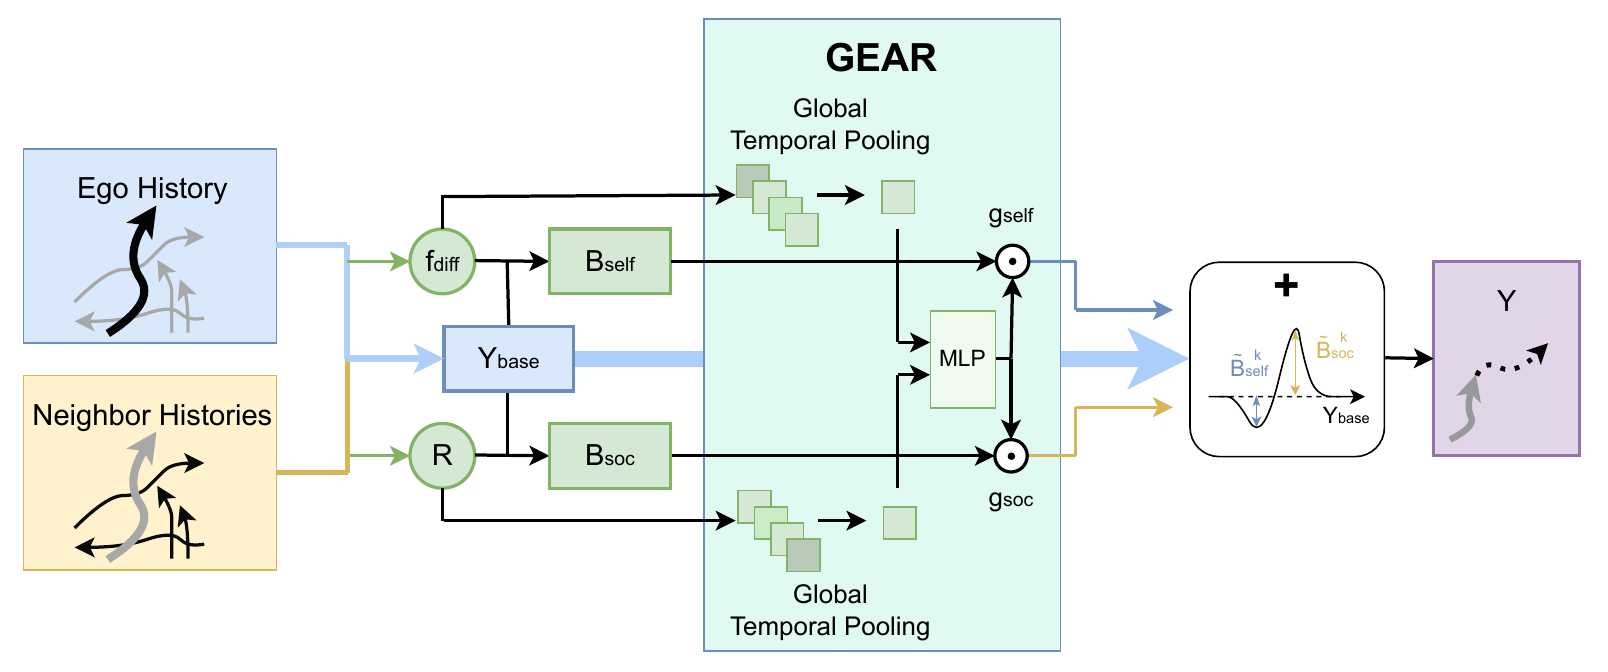
GEAR introduces generation-aware, step-wise activation gates that dynamically modulate self-motion and social-resonance biases before final trajectory composition. It adapts the influence of individual motion and social interactions across future prediction steps and scene densities.
GEAR: From Dynamic Encoding to Dynamic Activation in Social Trajectory Prediction
Jiaheng Chen, Jiaxing Li, Leixia Wang#, Jianan Ju, Tinghe Zhang (# corresponding author)
IEEE International Conference on Data Mining (ICDM) 2026
GEAR introduces generation-aware, step-wise activation gates that dynamically modulate self-motion and social-resonance biases before final trajectory composition. It adapts the influence of individual motion and social interactions across future prediction steps and scene densities.
A Unified Framework for Trajectory Prediction with Explicit Planning and Reaction Decomposition
Jiaheng Chen, Jiaxing Li, Tinghe Zhang, Chaopeng Guo# (# corresponding author)
ACM International Conference on Multimedia (ACM MM) 2026
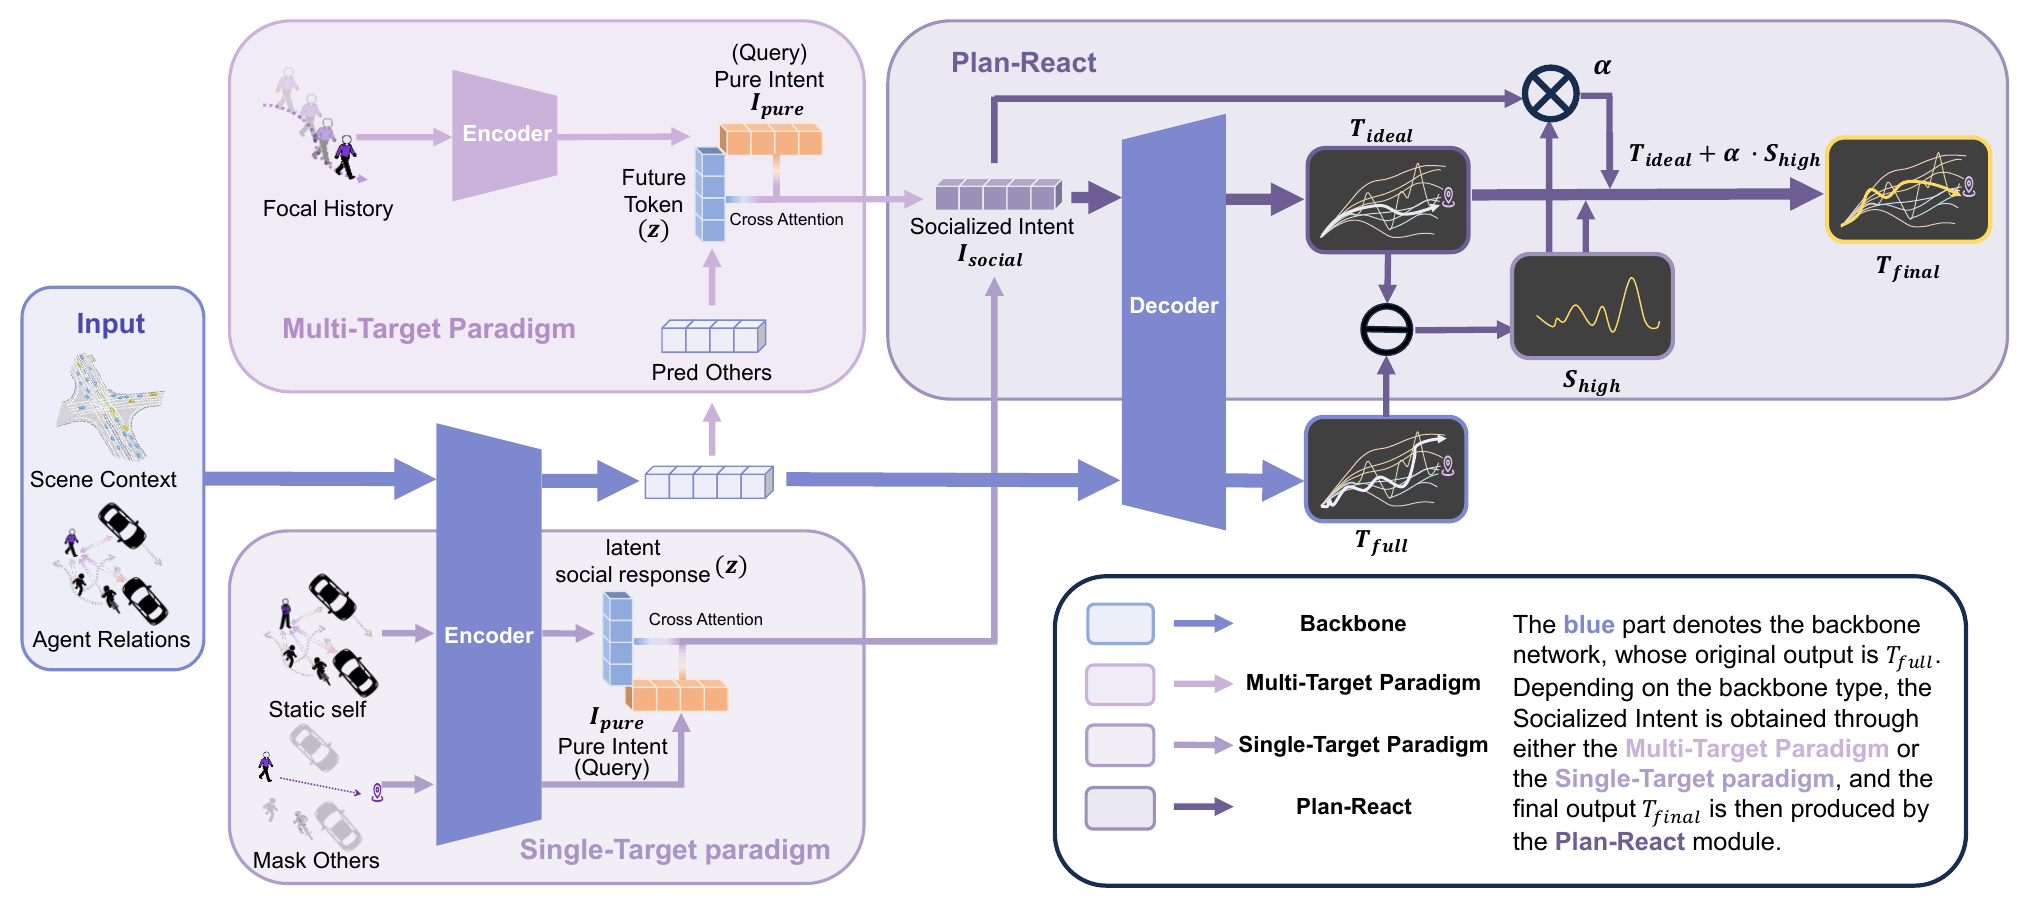
INTraJ decomposes social influence in trajectory prediction into planning and reaction: anticipating others' future behavior to construct reference trajectories, then recovering local reactive adjustments. The unified framework supports both multi-target and single-target prediction.
A Unified Framework for Trajectory Prediction with Explicit Planning and Reaction Decomposition
Jiaheng Chen, Jiaxing Li, Tinghe Zhang, Chaopeng Guo# (# corresponding author)
ACM International Conference on Multimedia (ACM MM) 2026
INTraJ decomposes social influence in trajectory prediction into planning and reaction: anticipating others' future behavior to construct reference trajectories, then recovering local reactive adjustments. The unified framework supports both multi-target and single-target prediction.